Kuiyang Yang · Computational designer & design engineer
From code
to object.
Scroll
I design with code — and build the systems that turn it into real things.
Software is precise. Machines, materials and people aren’t.
I build the tools that close that gap — so a new idea can be made, tested and shipped, not just rendered.
Hi, I’m Kuiyang
I build the tools between an idea and the machine that makes it — for products, robots and real-time 3D.
Design-to-production pipelines
Turning design intent into machine instructions.
Custom tools & plug-ins
Grasshopper, Python, C#, Revit API.
Robotics & computer vision
Toolpaths, machine testing, OpenCV.
Real-time 3D & visuals
TouchDesigner, GLSL, generative art.
Now · Nike Innovation · Computational Designer
Taking a brand-new manufacturing process from the lab to the design studio.
At Nike Innovation, I work on an emerging additive manufacturing process run on a 2D gantry. New processes are unpredictable — my job is to make this one understood, repeatable and ready for designers.
From machine testing to design exploration.
A loop, not a line. Each step taught me something about the machine — and every new design sent me back to refine the process.
The bridge between design and manufacturing.
01
Characterised how the process actually behaves
02
Built the pipeline that makes it controllable and repeatable
03
Opened it up for designers to explore
Practice · HKR Engineering · for MVRDV · 2020–22
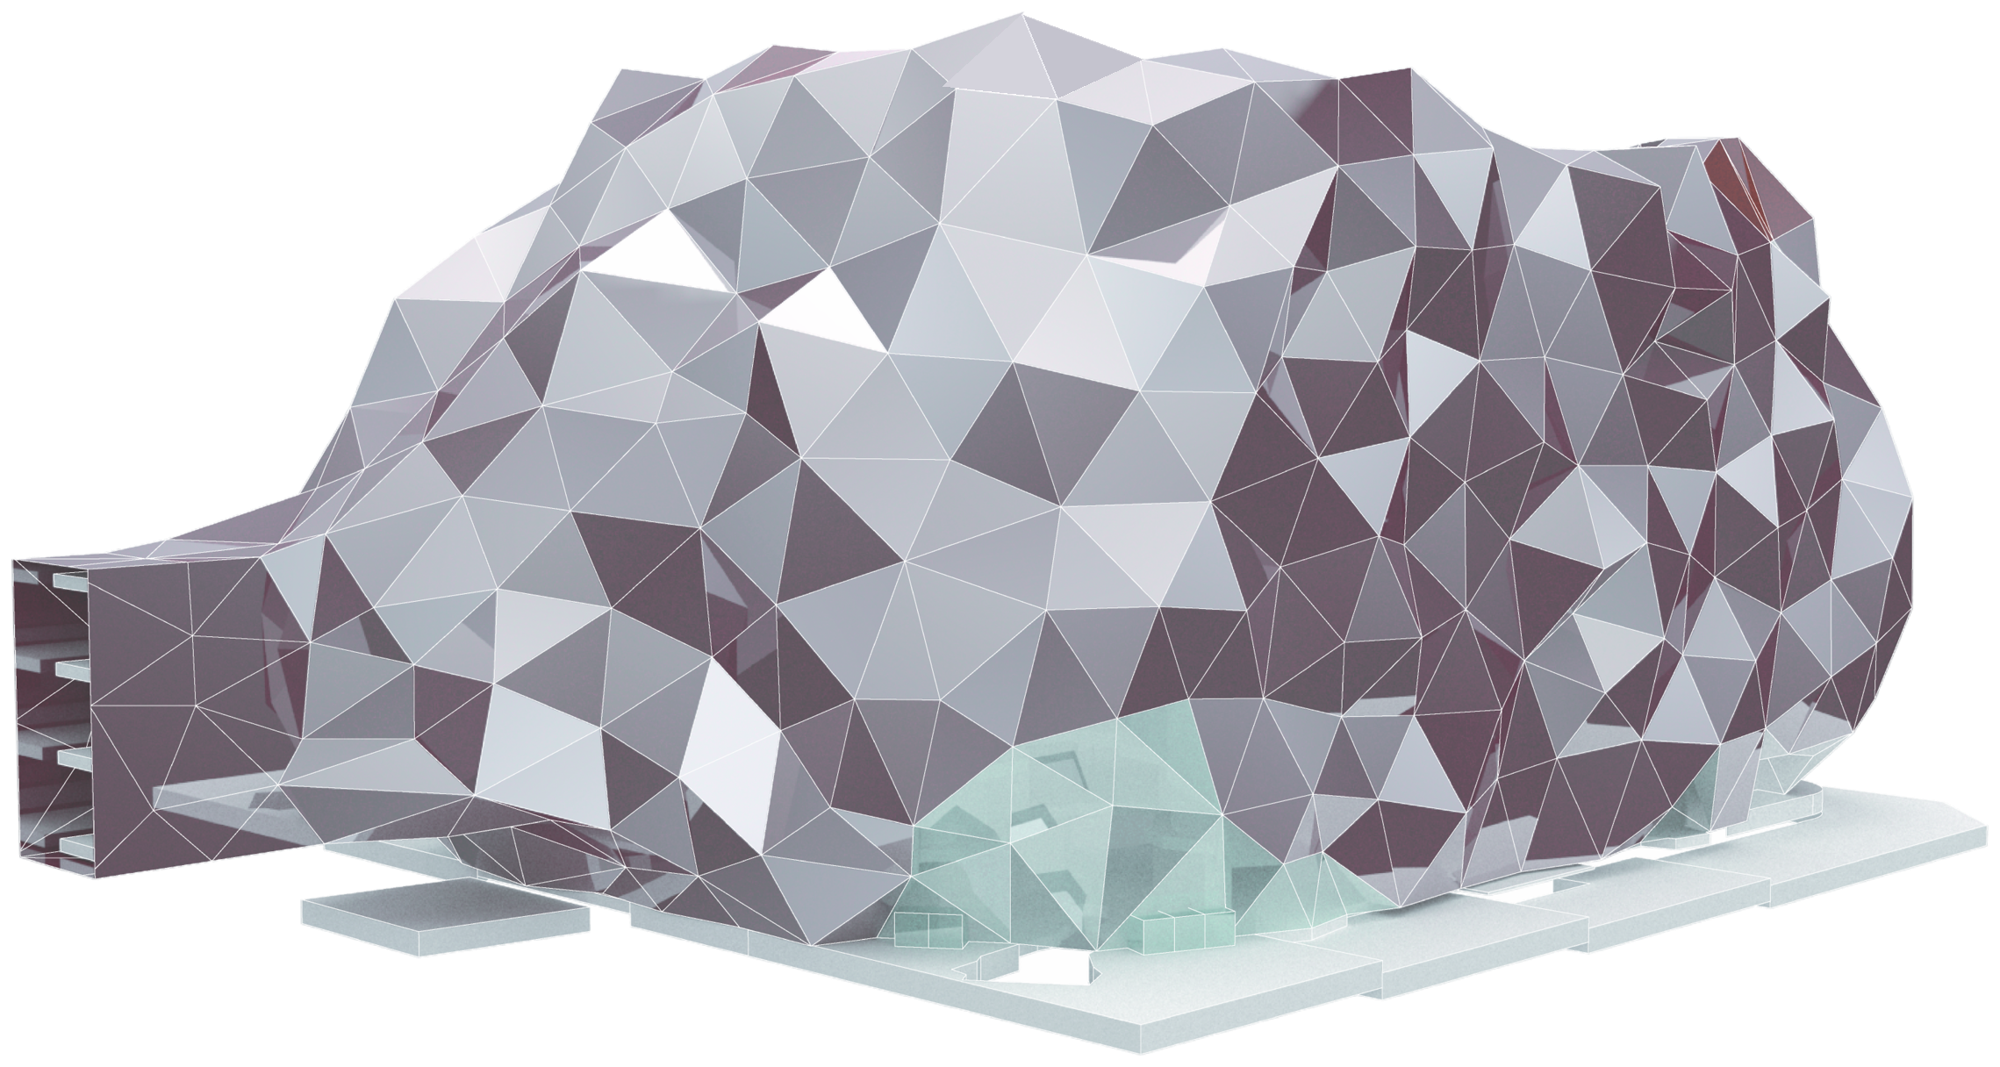
A façade where every panel is different — a mass-customisation problem.
MVRDV’s MetroWalk in Taiwan is wrapped in folded triangles, each with its own size and angle. Beautiful on screen; my job was to make it buildable.
One joint system, three conditions.
Upper, middle and lower panels meet the space frame at different angles. The same parts — disc plate, J-arm, U-bracket — adapt to all three, and Grasshopper clash-checked every placement.
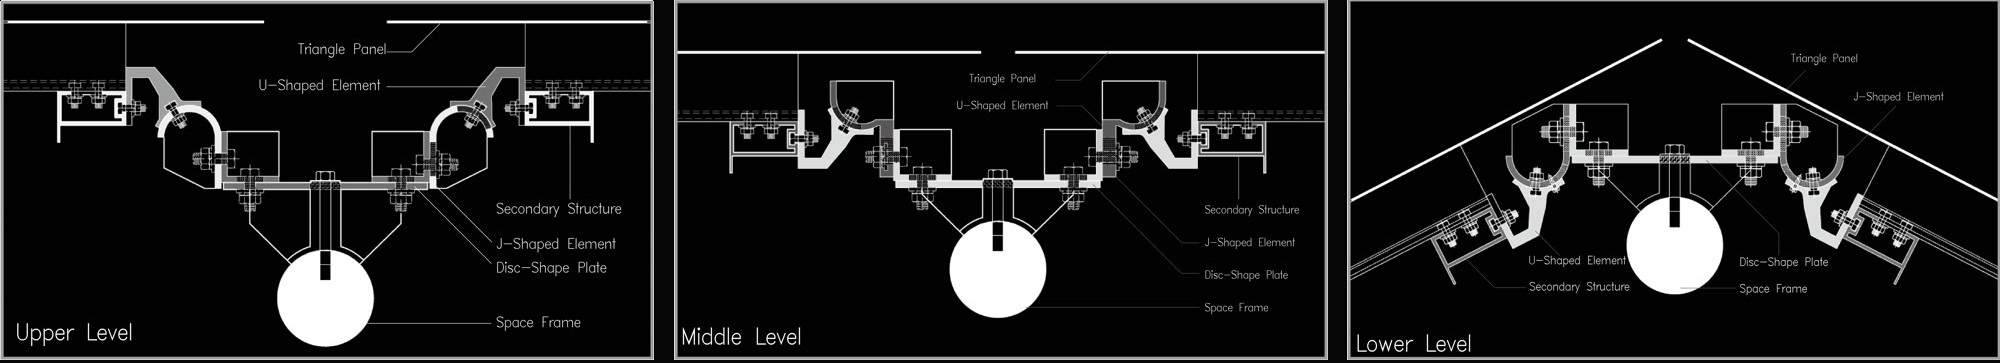
Three adjustments let one connector fit every panel.
Rotate the disc, slide the arm, tilt the bracket. Instead of thousands of custom parts, one adjustable joint — placed across the whole façade by script.
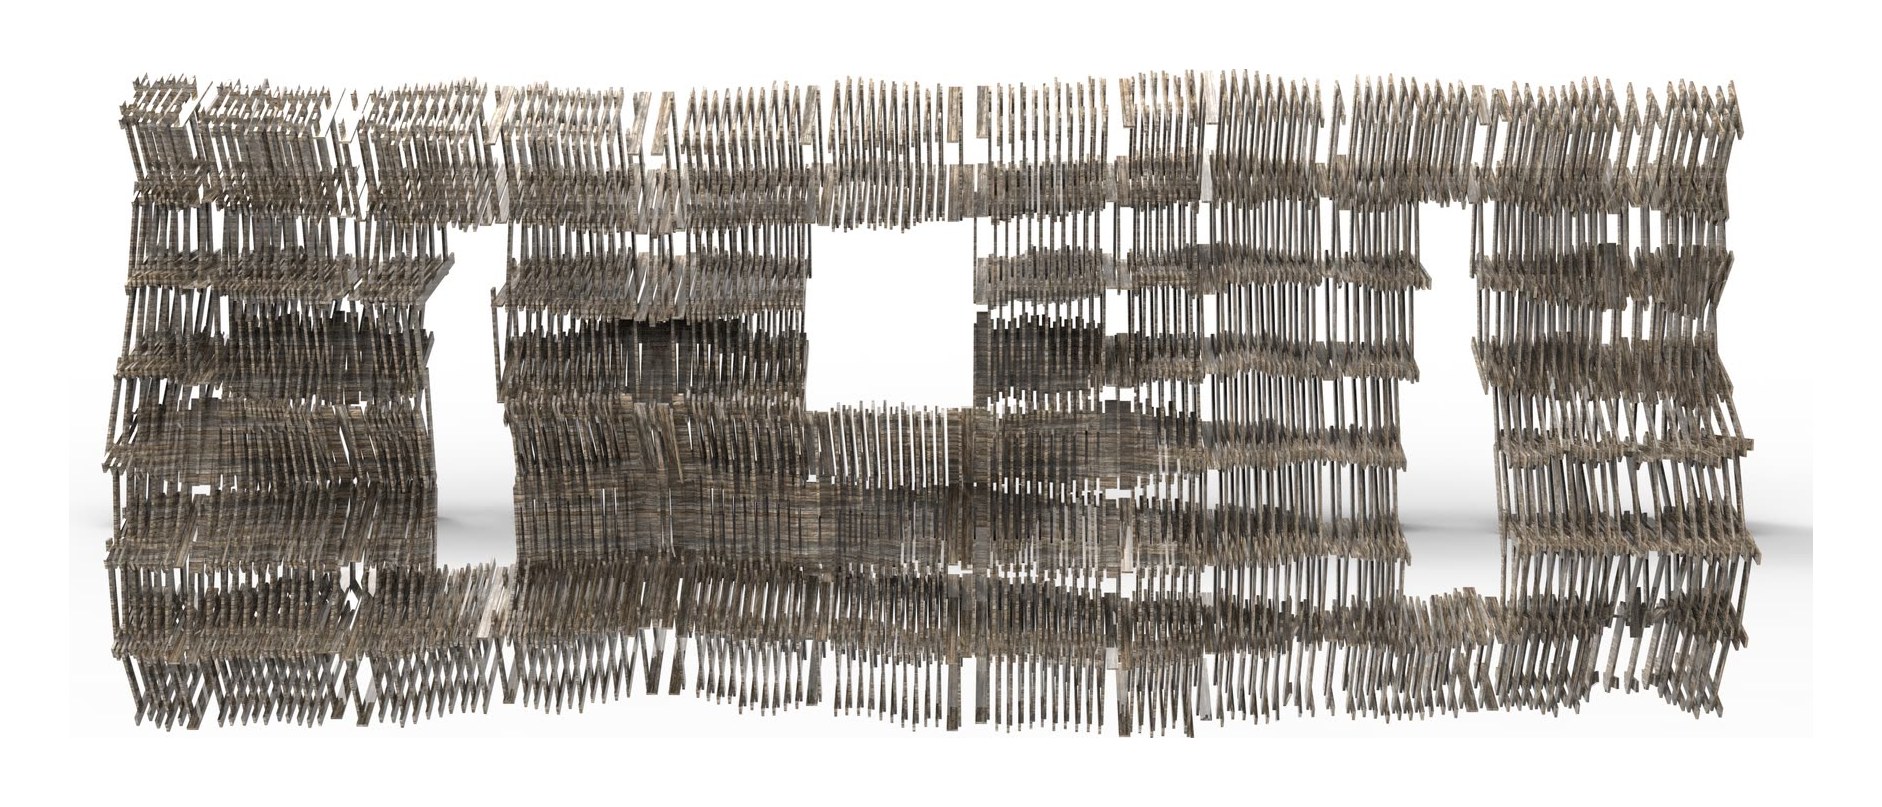
Research · CMU master’s thesis · Award · 2024
A robot that designs with whatever material it’s given.
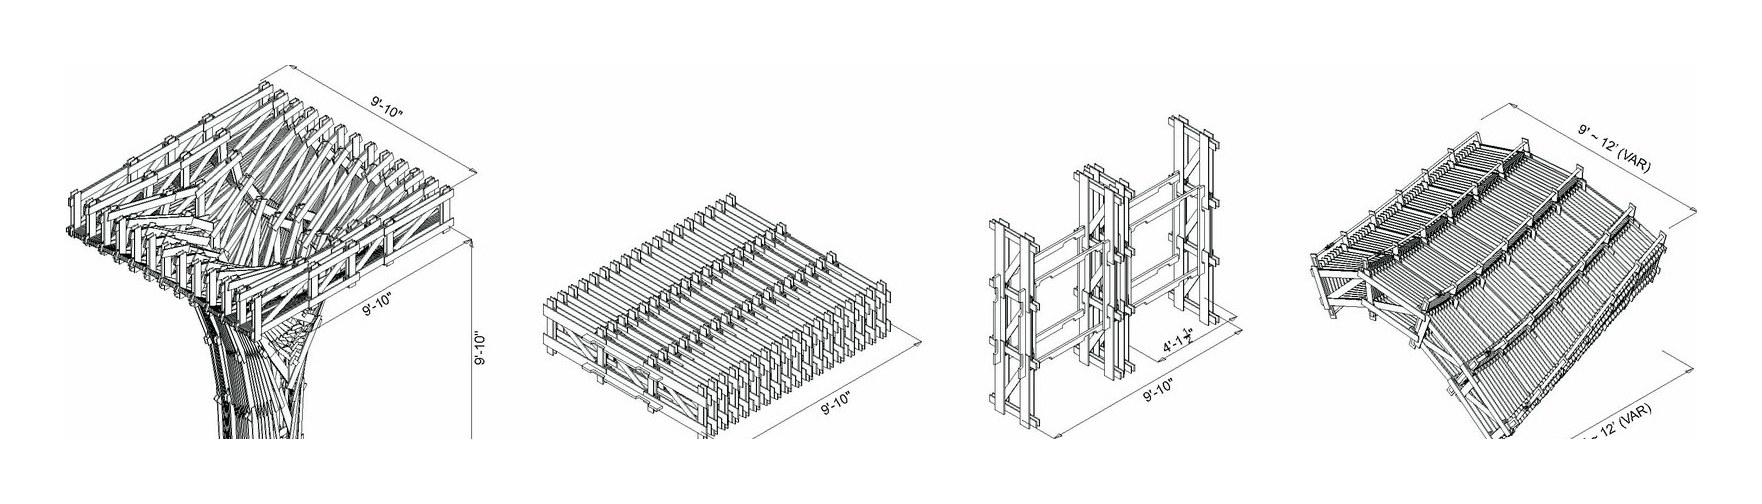
My thesis at Carnegie Mellon: building with reclaimed wood pallets, where no two pieces are alike.
The design can’t be fixed in advance — so the system decides piece by piece.
Instead of rejecting irregular material, the workflow adapts to it as it arrives.
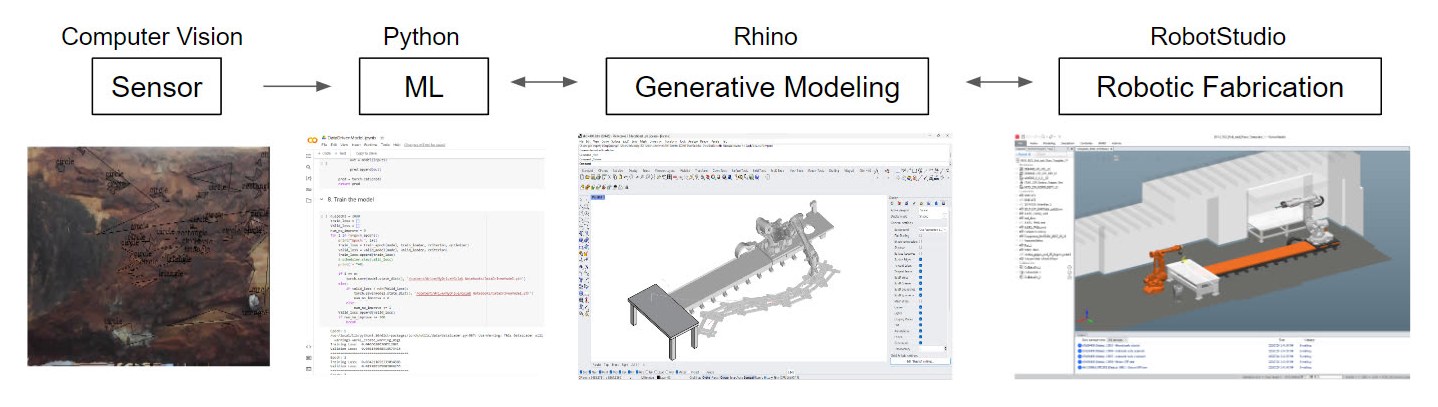
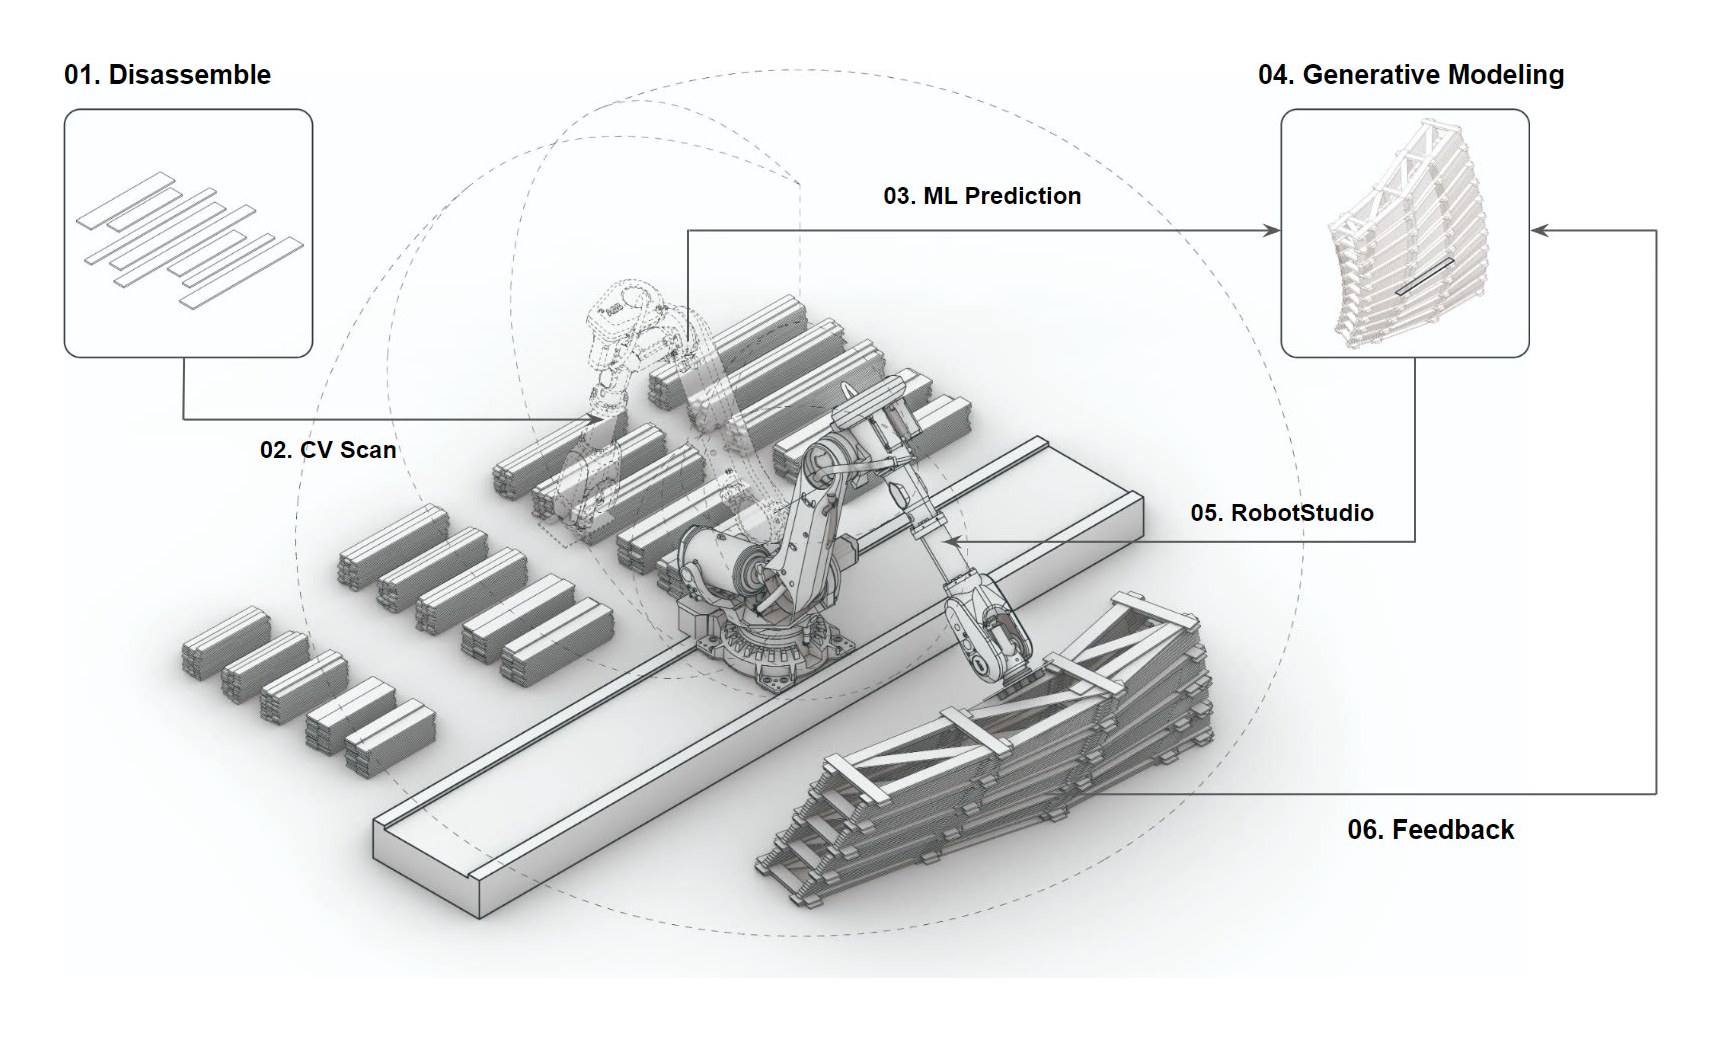
I wrote the system that reads each piece and tells the robot where it goes.
01 · See
A camera reads each board’s shape and condition.
02 · Decide
A generative model assigns it to a column, wall, façade or shell.
03 · Build
The robot stacks it — and the result feeds the next decision.
Art · Real-time · TouchDesigner
Art is where I play with no brief.
Outside work I make real-time art — systems of math, noise and sound that never play the same way twice. Same tools as my day job, different questions.
Dynamic Skeleton — 3,600 bars that move to sound.
Volume turns the body, the bass stretches every bar, every kick lights it up. Rebuilt for the browser from my TouchDesigner file — turn the sound on.
More live pieces in the Art room.
Play with the parameters of my generative work, then browse the full collection.
Enter the Art room →More work
Robotics · digital fabrication · material systems
Open to computational design · product & industrial design · design engineering · 3D art
Let’s build the
next thing.
Six years across product innovation, engineering and robotics research. Based in Portland, OR.